Full-Body Teleoperation
Whole-body teleoperation of a humanoid for live demonstrations and data collection.
- Teleoperation
- Humanoid
- Data Collection
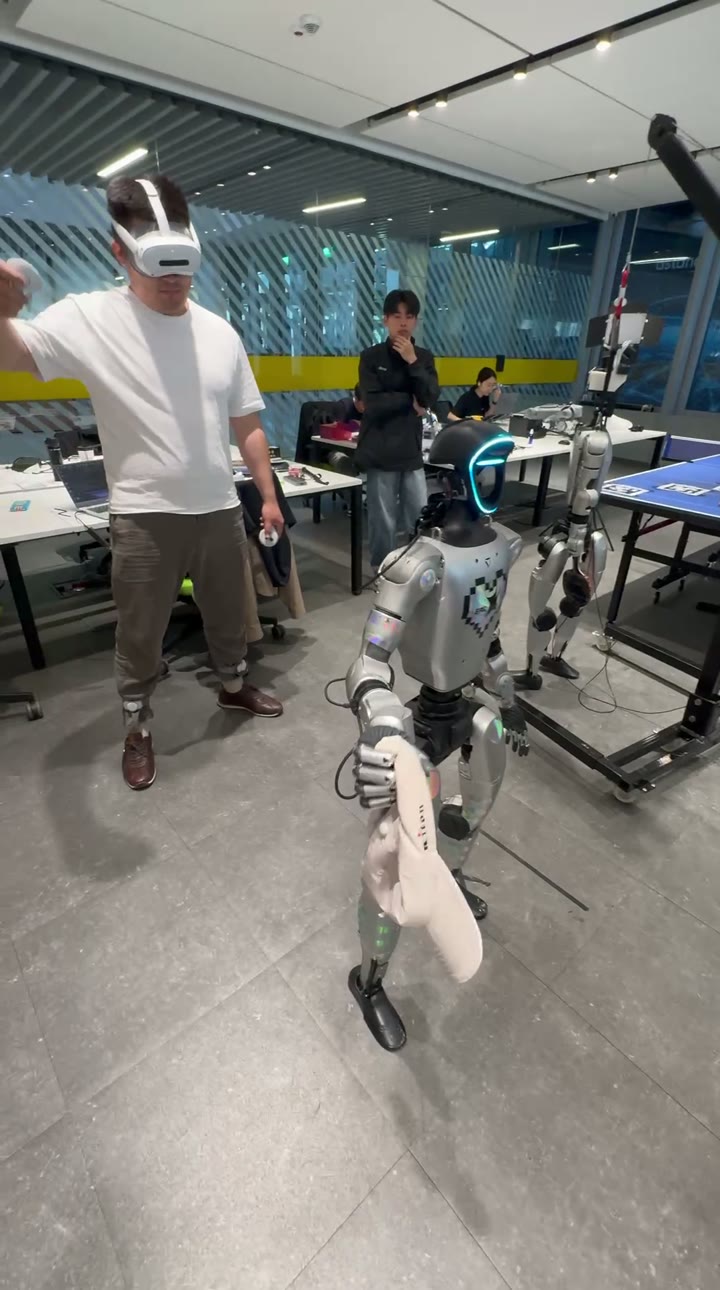
Overview
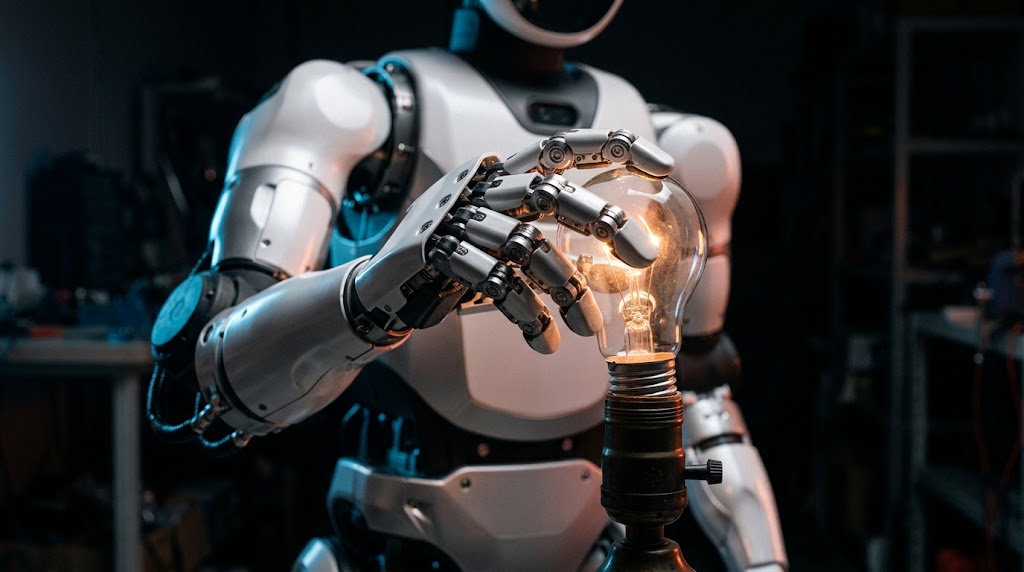
We built a teleoperation system that maps a human operator's full-body motion onto a humanoid robot in real time — arms, torso, hands and walking.
It serves two purposes: crowd-pleasing live demos, and recording high-quality demonstrations for training robot-learning models.
The Challenge
Human and robot bodies have different proportions and joint limits, so raw motion cannot be copied directly.
Latency has to stay low enough that the operator feels in control, while the robot must never be commanded into an unsafe pose.
Our Approach
Motion capture input is retargeted to the robot's kinematics in real time with joint-limit and self-collision constraints.
A balance-aware lower-body controller keeps the robot stable while the upper body follows the operator.
Every session is logged as synchronized camera, joint and command data, ready for imitation learning.
Results
- Real-time control with low perceived latency (placeholder — add measured latency)
- Hours of clean demonstration data collected for downstream training
- Used in public demos and client presentations
Tech Stack
- Unitree G1
- Motion capture
- ROS 2
- Python
- C++